Geared-Up · Pu Tai Senior High School · Team 10002X
Autonomous control
and robot iteration.
I competed in VEX Robotics for three years and mentored underclassmen for one year. The 2021–22 notebook identifies me as the main programmer; the 2023 team biography records my later role as captain.
View cropped notebook evidenceMy contributions
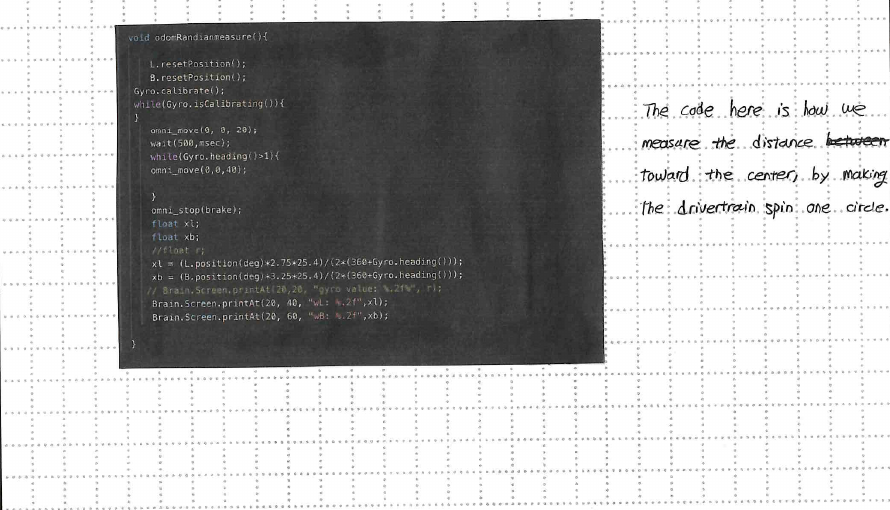
- Co-developed tracking-wheel and gyro-based odometry with a teammate, including a rotation routine to estimate tracking-wheel offsets.
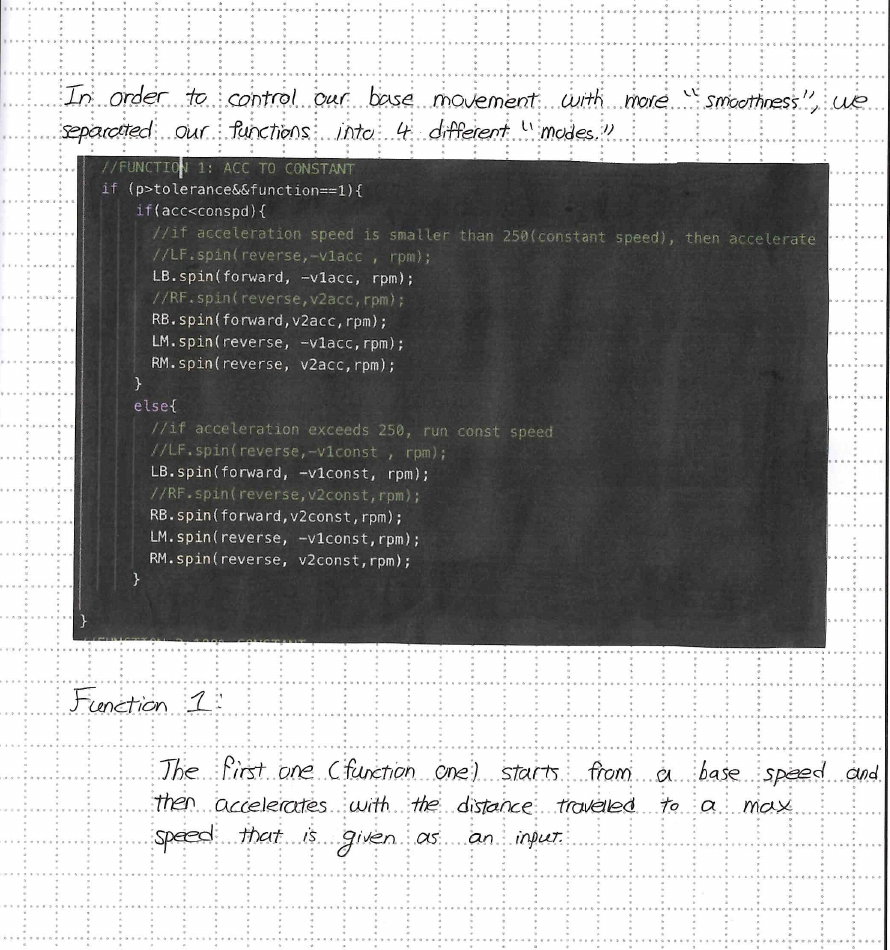
- Developed modular C++ autonomous motion routines with four modes: acceleration to constant speed, constant speed, deceleration, and combined acceleration/deceleration.
- Proposed a pneumatic ring-handling mechanism and collaborated on prototype iteration and robot integration.
How the work is documented
These cropped notebook excerpts show code, prototype photographs, and engineering notes. Names and signatures have been excluded from the public images.
Original notebook pages 44–49 document motion control. Pages 39–43 document the ring-handling prototype. In the original PDF these are pages 47–52 and 42–46 respectively.
A teammate and I developed the tracking algorithm. Teammates identified friction and release issues during prototype testing and proposed the trapdoor refinement. These were collaborative engineering decisions.
Design iteration
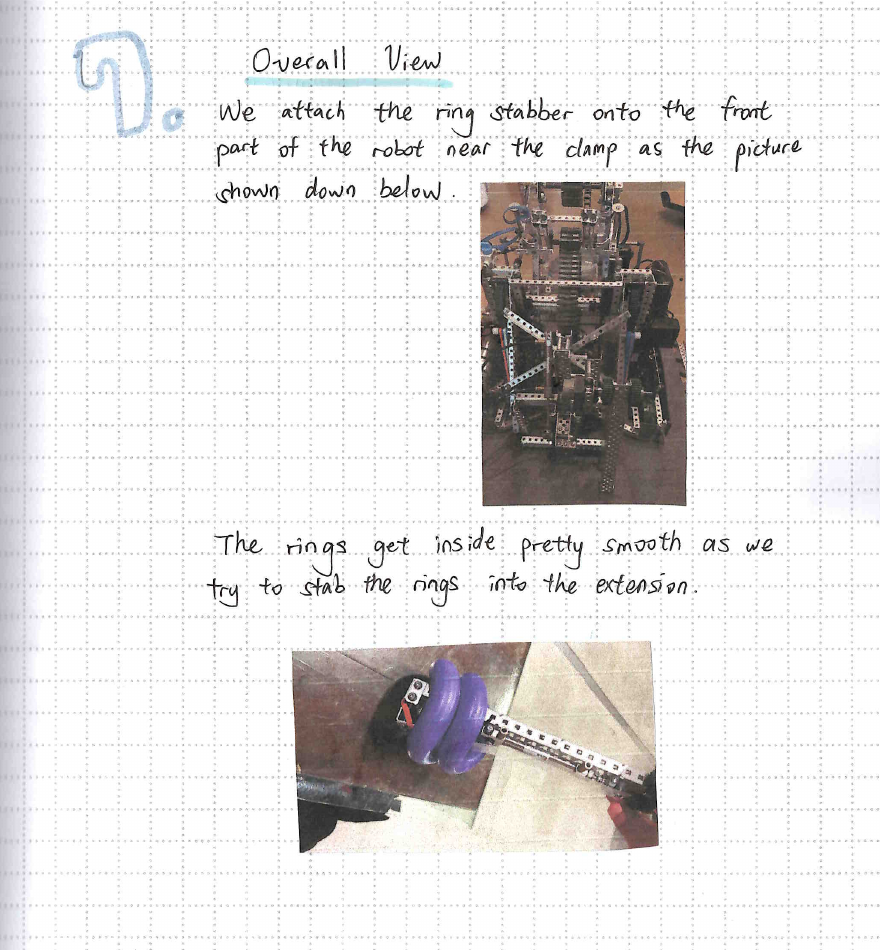
The initial ring-container concept used passive pickup and a pneumatic release. Testing exposed friction that made pickup and reset difficult. The team refined the mechanism with a one-way trapdoor and integrated it near the robot's front clamp.
The control routines were used to combine movement segments during autonomous operation. The notebook records qualitative observations; it does not establish a measured localization error or a quantified performance improvement.